SO-101 · MuJoCo · lerobot plugin
lerobot_env_so101
A pick-cube environment for the SO-101 arm where
every action dimension does something. Four dimensions, no dead
inputs, and a gripper command that means what it says. Runs as a plain
gymnasium environment; lerobot is optional.
The action space, drawn to scale
The vertical rule marks zero. For a position delta it
sits at the centre of the range; for grasp the same zero is the
left edge, because it is an absolute target — 0 is fully closed, not
"unchanged". That asymmetry is the whole action space:
Box([-1, -1, -1, 0], 1.0, (4,), float32).
The upstream gym-hil port this came from declared three more dimensions that
the IK solver silently discarded:
SO-101's 5-DOF arm cannot track a 6-DOF Cartesian pose, so a policy could spend capacity learning to depend on inputs that had zero effect on the simulation. Verified rather than assumed: perturbing each of the four remaining dimensions moves the state — 0 of 4 dead. See Action space.
What it looks like
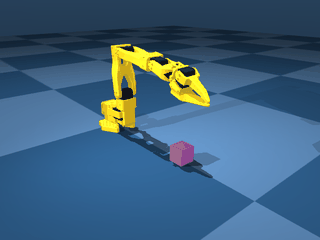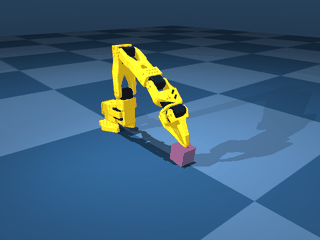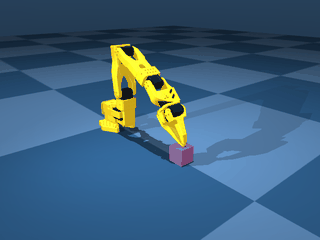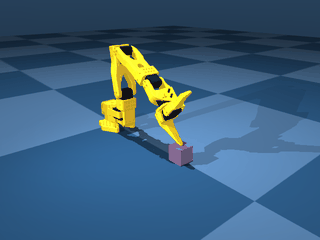
A hand-written controller driving a reach→gripper-close motion — not a successful pick-and-lift. A top-down grasp is not yet reachable with the position-only IK; see Limitations.
Two more things the upstream port got wrong
- The gripper was an increment.
grasp=0used to mean "leave it alone"; it now means "fully closed", mapped onto the actuator's native radian range. This is a breaking change as of v0.2.0. - Sparse-mode success ignored the gripper. Upstream computes a strict success check, then replaces it with a lift-only test in sparse mode. Measured here before the fix: the gripper 0.092 m from the block (threshold 0.05 m), block lifted 0.20 m, reported as success. A block knocked upward counted as a pick.
Both are detailed in What changed vs. the upstream port.
Where to go next
| If you want to | Read |
|---|---|
| Run your first episode | Getting started |
| Use it from lerobot's CLI or a policy | Using it with lerobot |
| Understand what the 4 action dimensions do | Action space |
| Debug a crash or a surprising result | Limitations and troubleshooting |
| Look up a class or argument | API reference |
License and attribution
Apache-2.0. The SO-101 MJCF/URDF and the original control code were authored by
Paul Loh (github.com/lohpaul9) and ported from
lohpaul9/gym-hil; the base gym-hil
project structure is Copyright 2024 The HuggingFace Inc. team. Full attribution
is in Using it with lerobot.